Projects
Research and engineering projects, from multi-drone coverage control and autonomous vessels through to underwater gliders and fixed-wing UAV development.

Multi-Drone Image Sampling with Online Map Feedback
Coverage control for drone teams that closes the loop with the 3D reconstruction itself — the evolving mesh tells the fleet where the map is still unresolved, and the controller flies them back there.
View project
Angle-Aware Coverage Control for 3D Map Reconstruction
Coverage control that treats viewing angle as part of the state, so a drone team collects the images a 3D reconstruction actually needs — extended to large fields, steerable cameras and battery-limited missions.
View project
Drone Coverage Control for Moving Target Tracking
Adapting a drone's altitude and its object-detection model in real time, so detection accuracy and field of view stay matched to how the target is moving.
View project
Safe Autonomous Ship Operation in a Port
Hierarchical control for autonomous vessels manoeuvring inside a port, combining model predictive control with control barrier function safety certificates.
View project
Predictive Multi-Robot Task Allocation for Radiation Monitoring
UAV and UGV teams dispatched across a thermosolar plant to map direct normal irradiance, with a receding-horizon allocation that anticipates where measurements will matter next.
View project
Multi-Robot Environmental Sampling with Online Gaussian Processes
Estimating a scalar field — soil chemistry, irradiance, water quality — from readings a robot team takes at discrete points, with a Gaussian process saying where the estimate is still weakest and a two-layer controller getting the robots there.
View project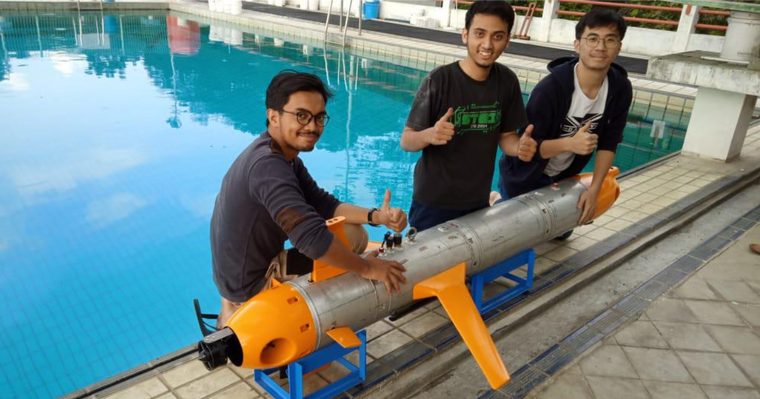
Hybrid Autonomous Underwater Glider
A long-endurance underwater platform combining AUV propulsion with buoyancy-driven glider motion, taken from design through lake testing.
View project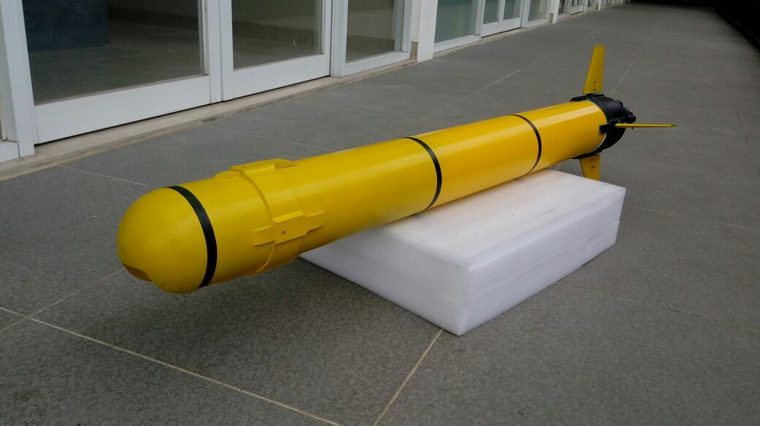
Arnadyaksa — Low-Cost Autonomous Underwater Vehicle
An affordable UUV for coral reef monitoring, using controlled buoyancy and a single motor to keep both cost and power draw low.
View project
VR Interface for Drone Swarm Teleoperation
Flying a drone swarm from inside a VR headset, with formation control holding the shape and a control barrier function keeping it safe — and a measurement of what that interface actually costs the operator.
View project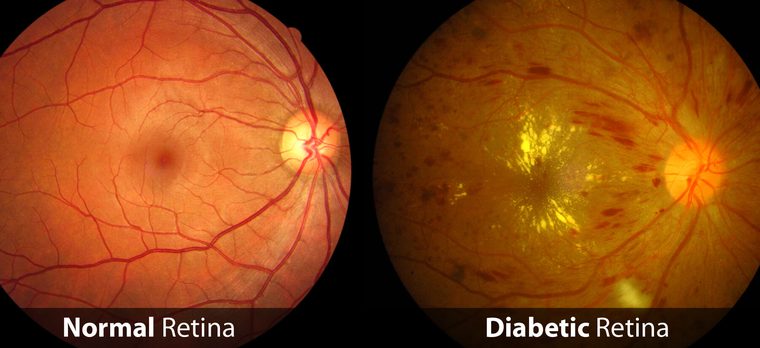
Automatic Screening for Diabetic Retinopathy Severity
Deep learning models for grading diabetic retinopathy severity from retinal fundus images, built on EfficientNet.
View project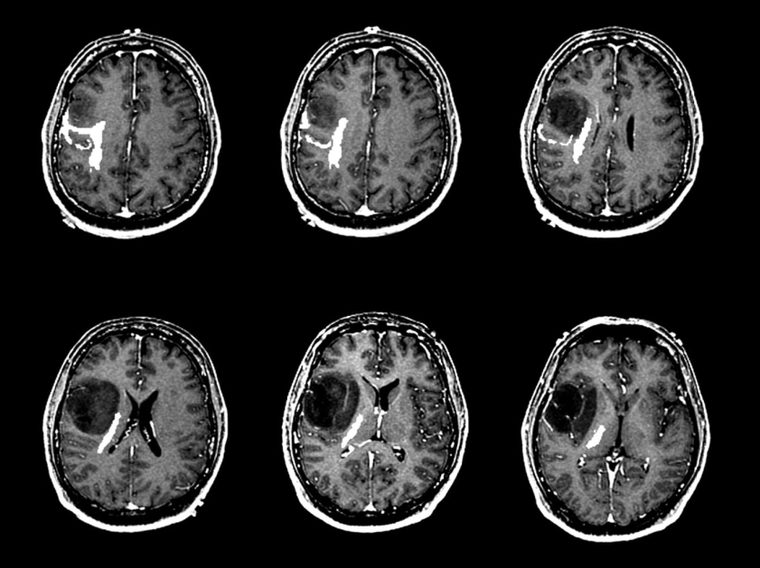
CNN-based Brain Tumor Classifier
A convolutional neural network that classifies brain tumours from MRI into three types — glioma, meningioma and pituitary tumour.
View project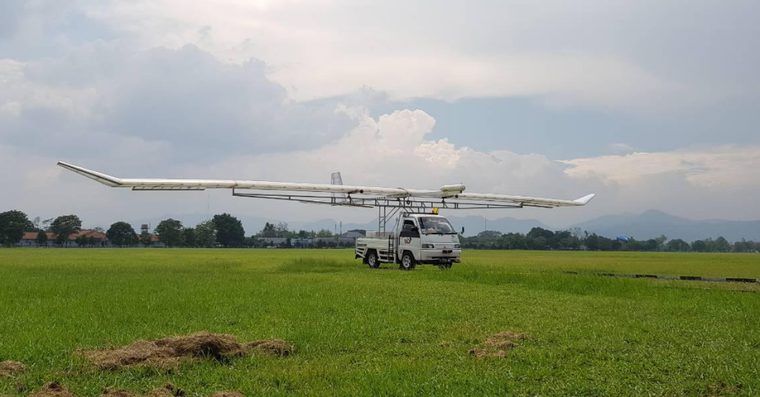
HALE — High-Altitude Long-Endurance UAV
Control and monitoring systems for a high-altitude long-endurance UAV with a 21-metre wingspan.
View project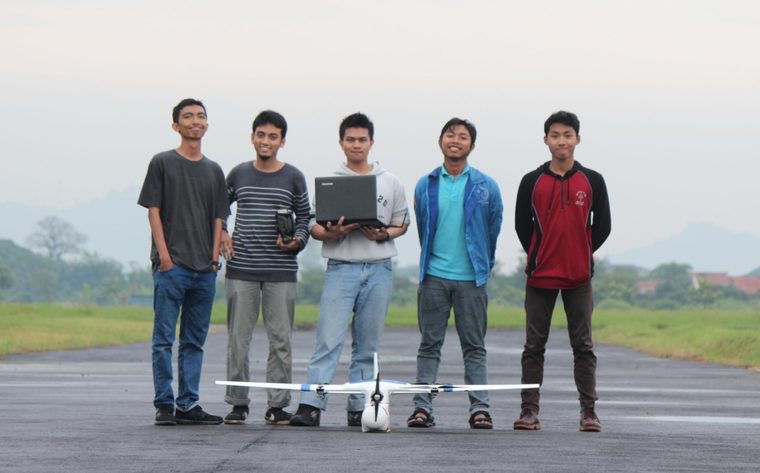
Beyond Skyline — High-Altitude Mini UAV Flight
A 1.5-metre-wingspan UAV flown to 10,000 feet above ground level carrying weather monitoring and live video, as preparation for the HALE programme.
View project
Tube-Launched Folding-Wing UAV
A compact fixed-wing UAV that stows in a tube and deploys without a runway, with a coordinated relay system to extend communication range. Best Design, Indonesia Aerial Robotics Competition 2017.
View project
Gatotkaca Ganesha — Hybrid VTOL UAV
A fixed-wing UAV that takes off and lands vertically like a multicopter, pairing rotary-wing manoeuvrability with fixed-wing endurance. 1st Runner-Up, Indonesia Aerial Robotics Competition 2016.
View project